// about // experience // projects // skills // contact
> INITIALIZING SYSTEMS...


I build the hardware. I write the firmware. I ship the robot.

πŸ“ Bengaluru, India  |  Available for opportunities
OSCILLOSCOPE - CH1  SIGNAL DEMO
CH1 5V/div CH2 3.3V/div 1ms/div

I'm an Embedded Systems & Robotics Engineer in Bengaluru who started building at age 10 with syringes and cardboard. I'm hardware first: I design the electronics, write the firmware and ship the robot.

For nearly two years at Fubotics I was the technical lead, and for the first year the only technical person, building facade and duct cleaning robots with the IoT backend behind them. Now at Integra Robotics I work on collaborative robots, from control electronics to a gripper.

I've tested robots on the sides of buildings and hand-soldered drivers at 2AM.

// Only a few explosions.

nish@robotics:~$ status
> EXPERIENCE 3+ years across robotics, industrial automation and kinetic art
> COMPANIES 4 (Param, CraftTech, Fubotics, Integra)
> ROBOTS 3 types, deployed to production
> CGPA 8.68 | VTU | ECE | First Class Distinction
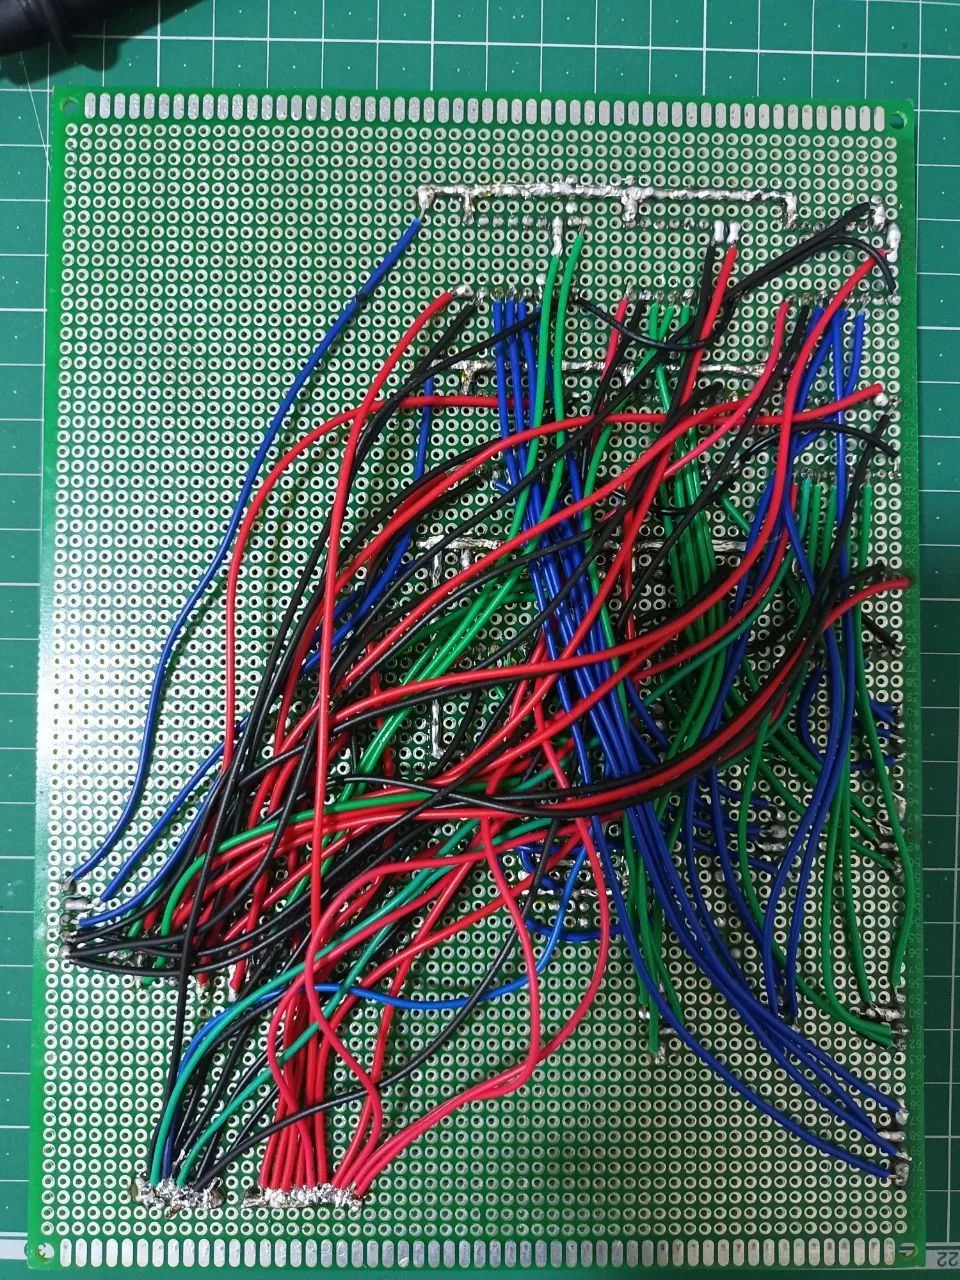
> SOLDERING hand-spun perfboard TMC drivers
> LOCATION Bengaluru, India
> STATUS OPEN TO OPPORTUNITIES

Where I've shipped robots.

Integra Robotics
Electronics and Robotics Engineer
⏱ Jun 2026 - Present πŸ“ Bengaluru
  • Built, integrated and tested the control box and pendant for the company's collaborative robot, including multi-rail 48V power distribution.
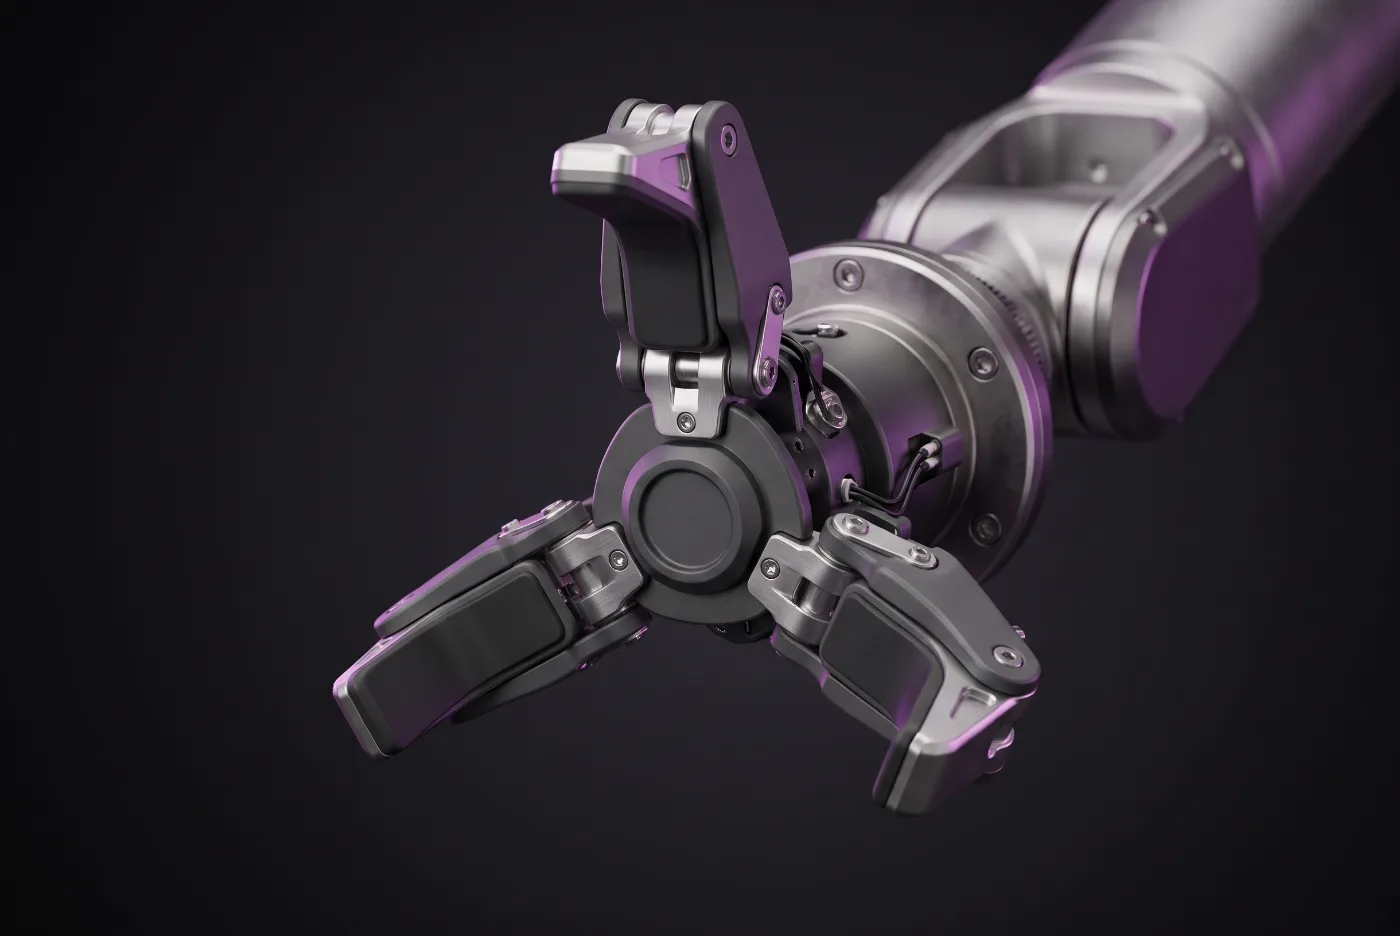
  • Designed a tripod gripper: the finger mechanism, electronics and firmware, with its limits documented. The mechanical team refined it from prototype prints to machined aluminium.
  • Built the full gripper software: a control and monitoring app with a real-time 3D view of live finger force, calibration, logging and slip detection, plus a Python SDK that lets any cobot use it as a single device.
  • Provided electronics engineering and system integration across product lines owned by other teams: power design, wiring, schematics, commissioning, testing and fault resolution on UGVs, cobots and robotic arms.
  • Produced schematics and bills of materials for custom PCBs, documented, with fabrication managed through an outside vendor.
Fubotics Private Limited
Technical Lead
⏱ Aug 2024 - May 2026 πŸ“ Bengaluru
  • Sole technical person for first year β€” full ownership: mechanical design, electronics, firmware, IoT backend, and team management
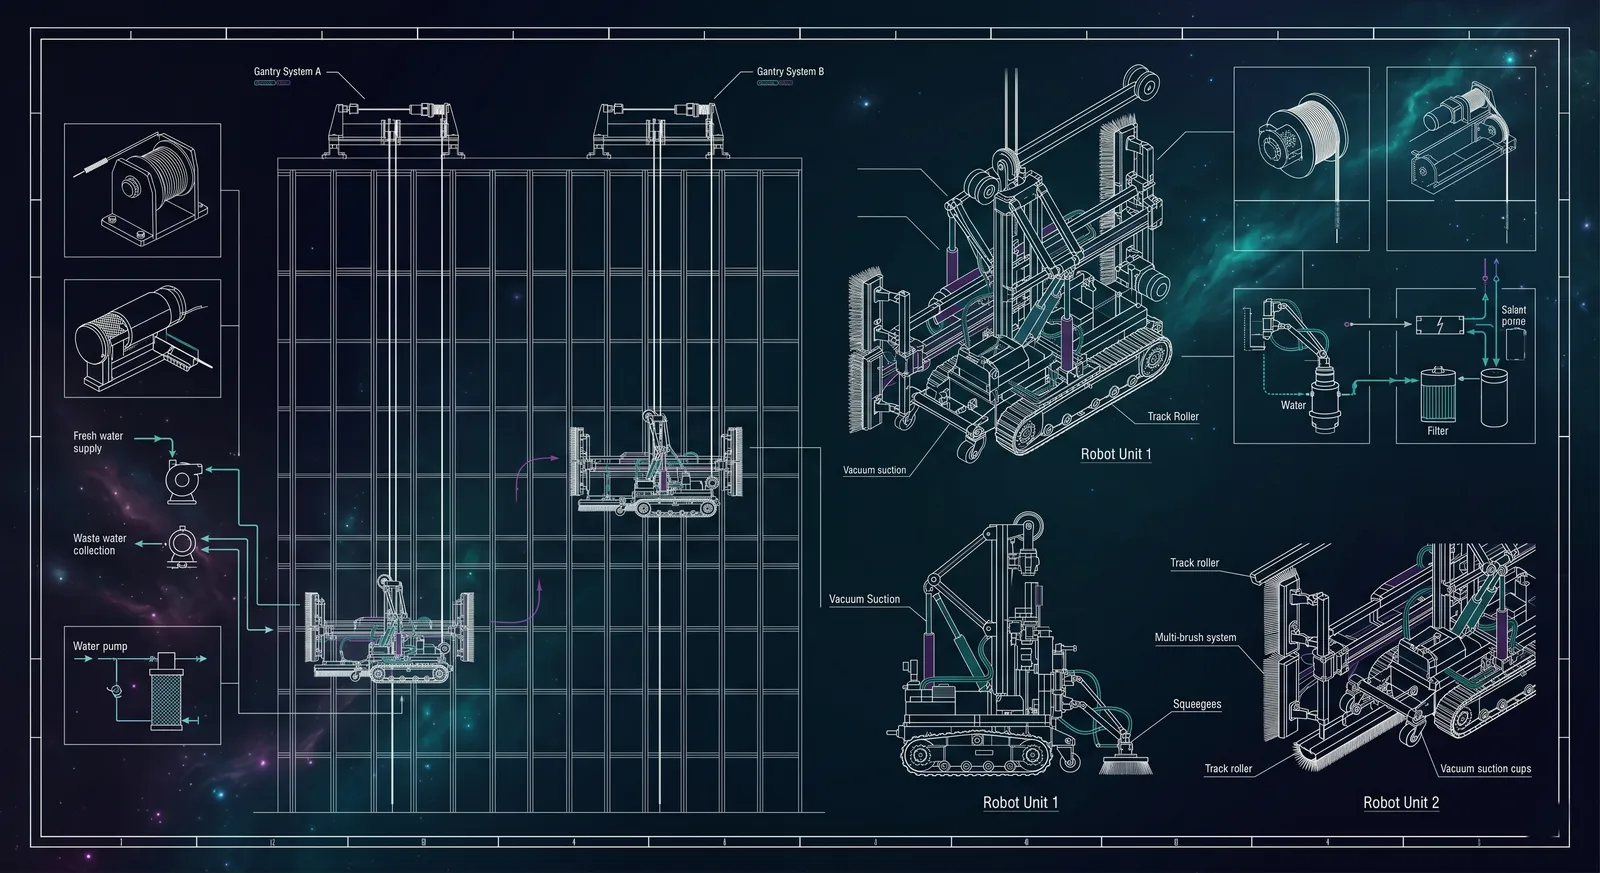
  • Built Facade Cleaning Robot V1 & V2 (tested on 20m building); independently developed industrial duct cleaning robot β€” camera-guided, cable-tethered, RS485 + RJ45 camera integration; implemented basic SLAM-based navigation and path planning using FreeRTOS on ESP32 for autonomous movement inside ducts; multiple units deployed
  • Engineered LoRa-to-WiFi bridge to solve 3-phase motor interference β€” 15 days before deployment
  • Managed component sourcing from 30+ suppliers; led team of 4–5 interns & 2 employees; built Compass, an internal R&D OS with RAG AI assistant (React, Supabase, pgvector, Gemini 2.5 Flash)
Craft Tech 360
Embedded Hardware Engineer
⏱ Apr 2024 – Jul 2024 πŸ“ Bengaluru
  • Built DMX-controlled LED systems and stepper/linear actuator control for stage production automation
  • Developed golf swing analyzer β€” IMU wearable sensor tracking speed, angle, and motion in real-time
Param Innovations
Junior Embedded Engineer
⏱ Jul 2023 – Mar 2024 πŸ“ Bengaluru
  • Drove ~90% of Kinetic Wave installation β€” 20+ synchronized stepper motors, hand-soldered TMC2209 driver perfboards from scratch
  • Electronics orchestrator across 4–5 kinetic art installations in production environments

Beyond the build.

nish@volthub:~$ cat overview.info
⚑

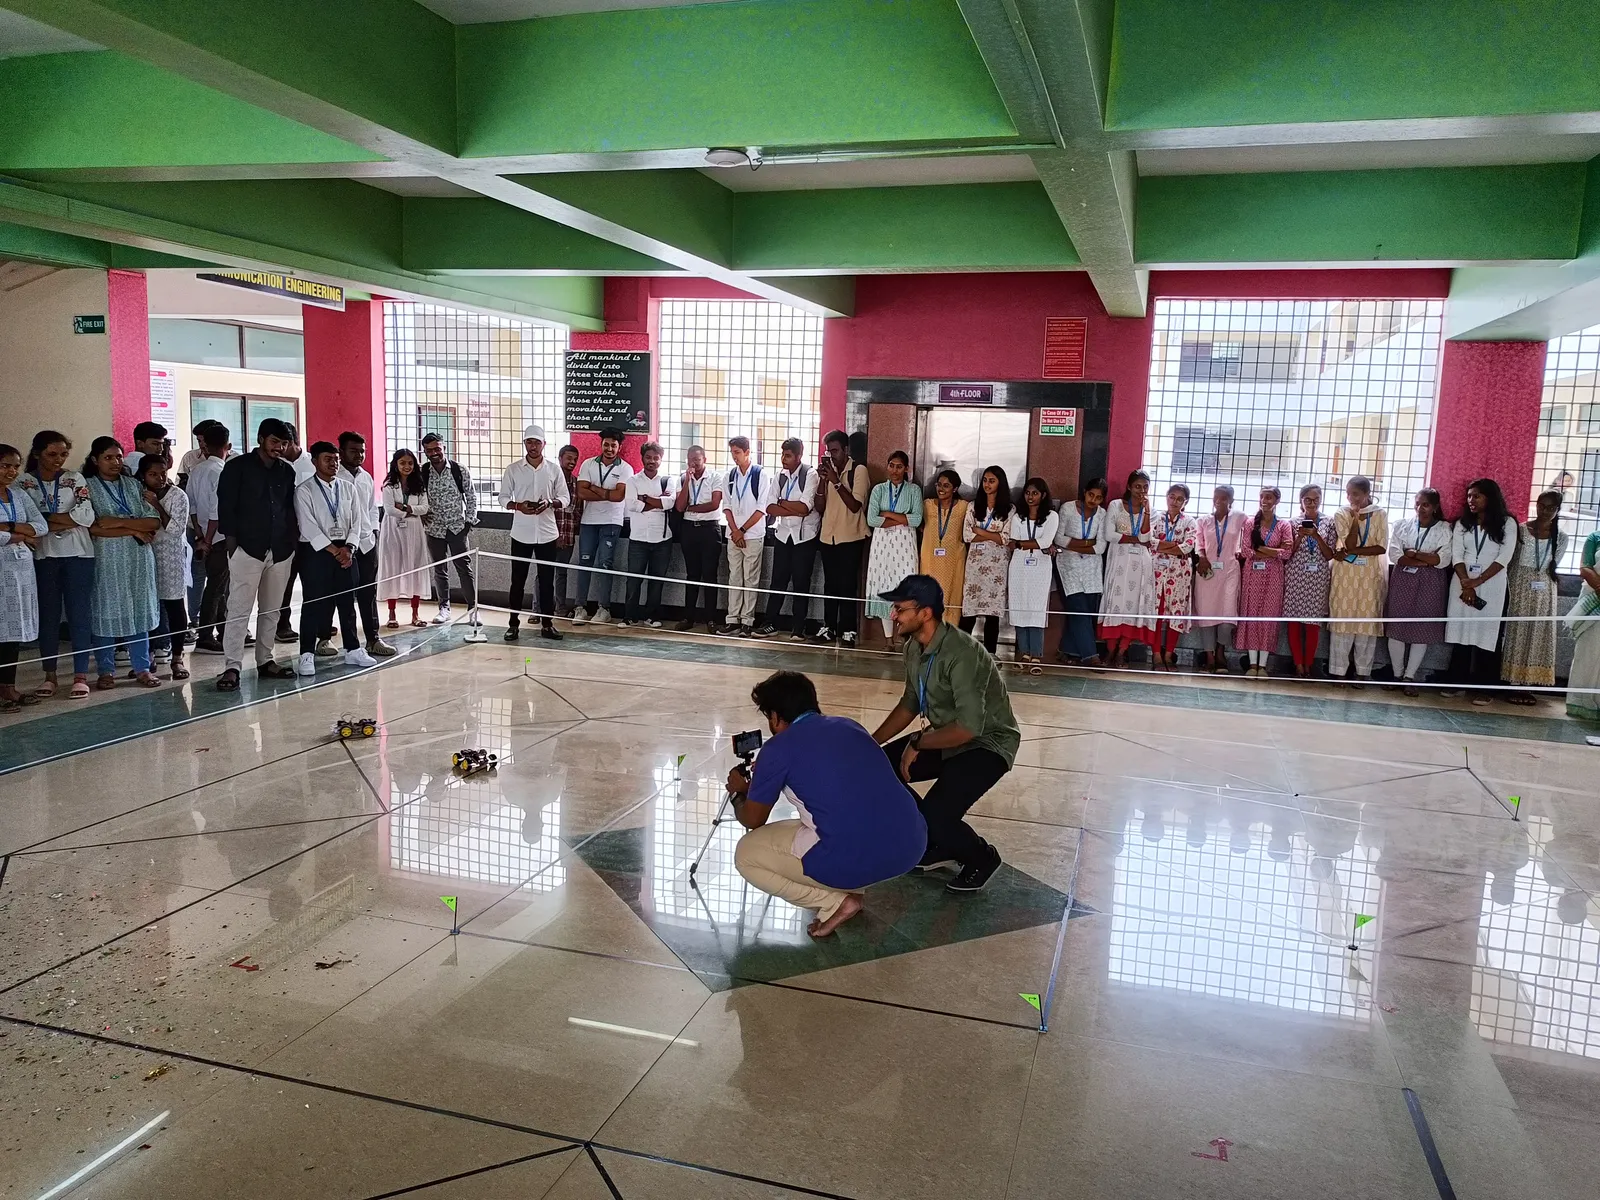
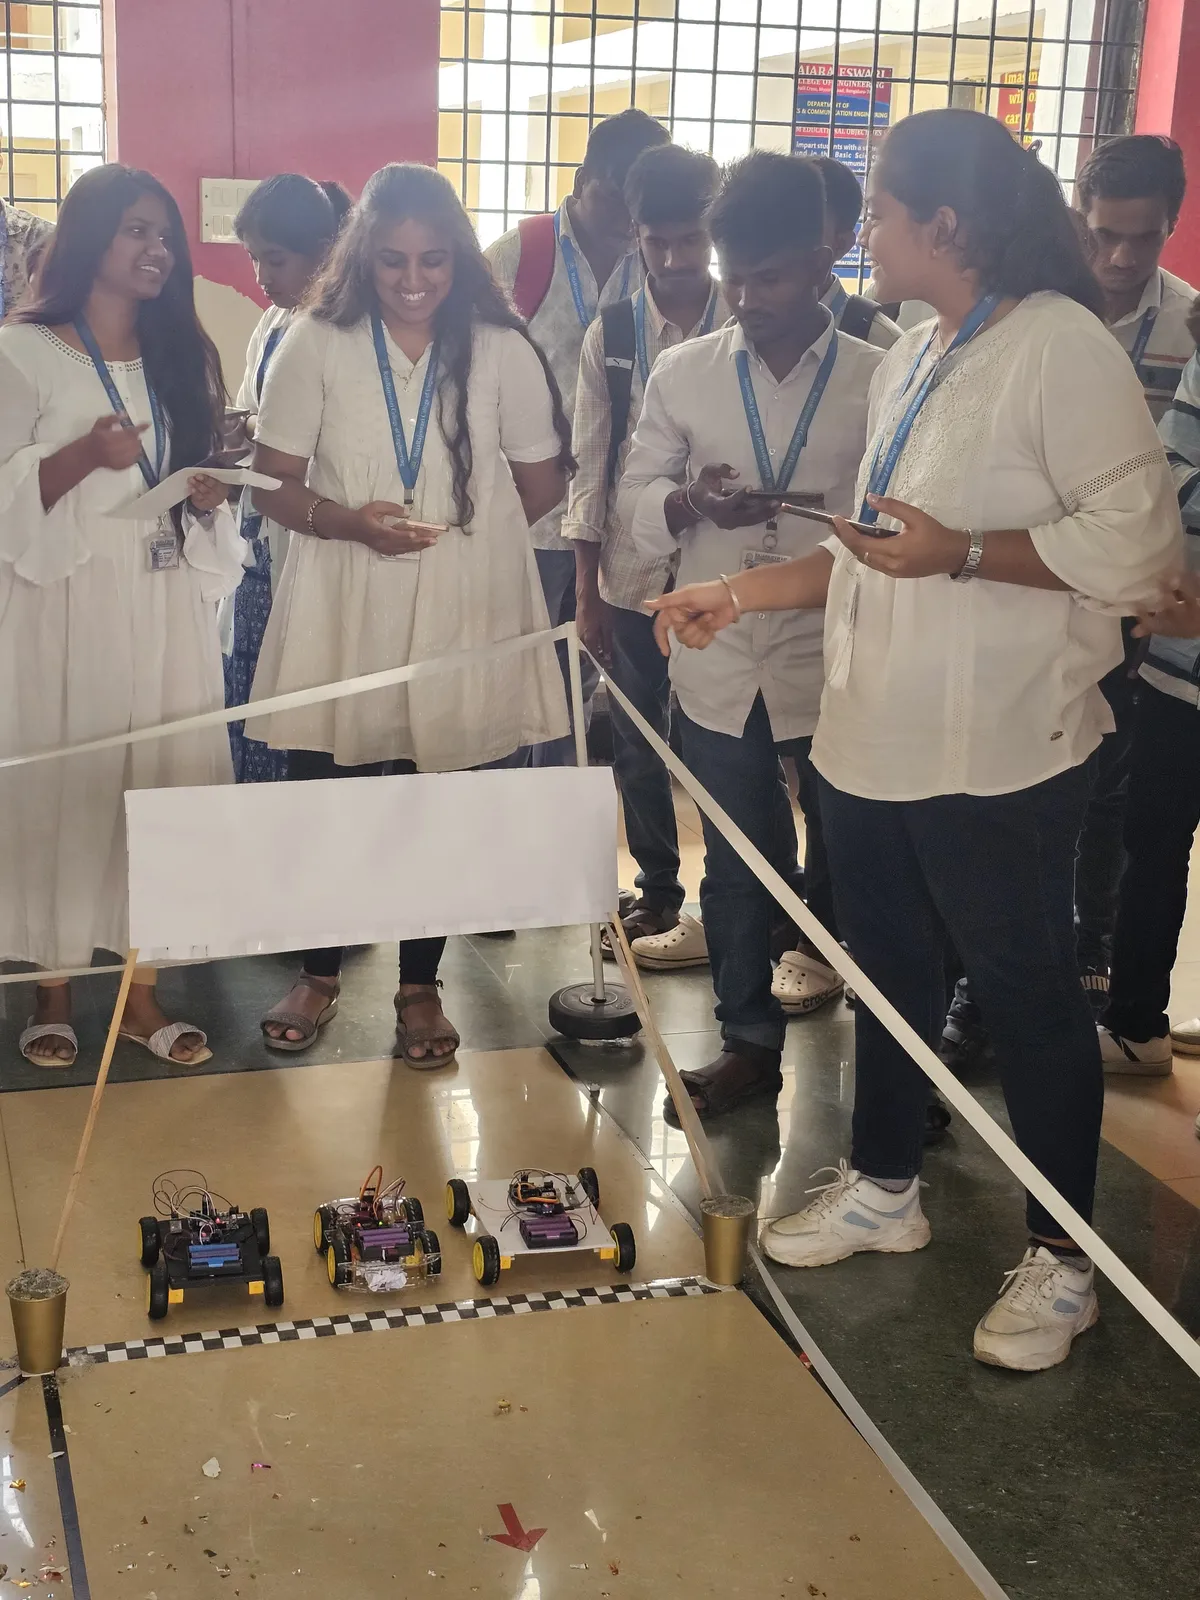
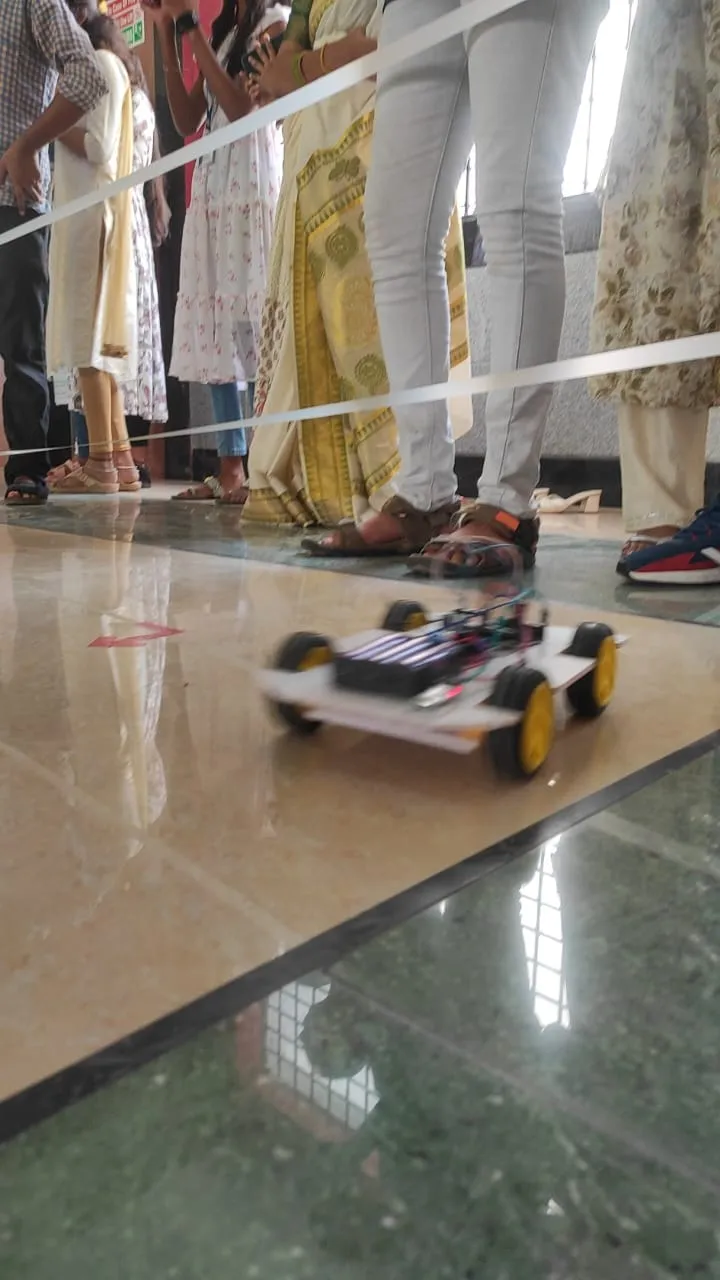
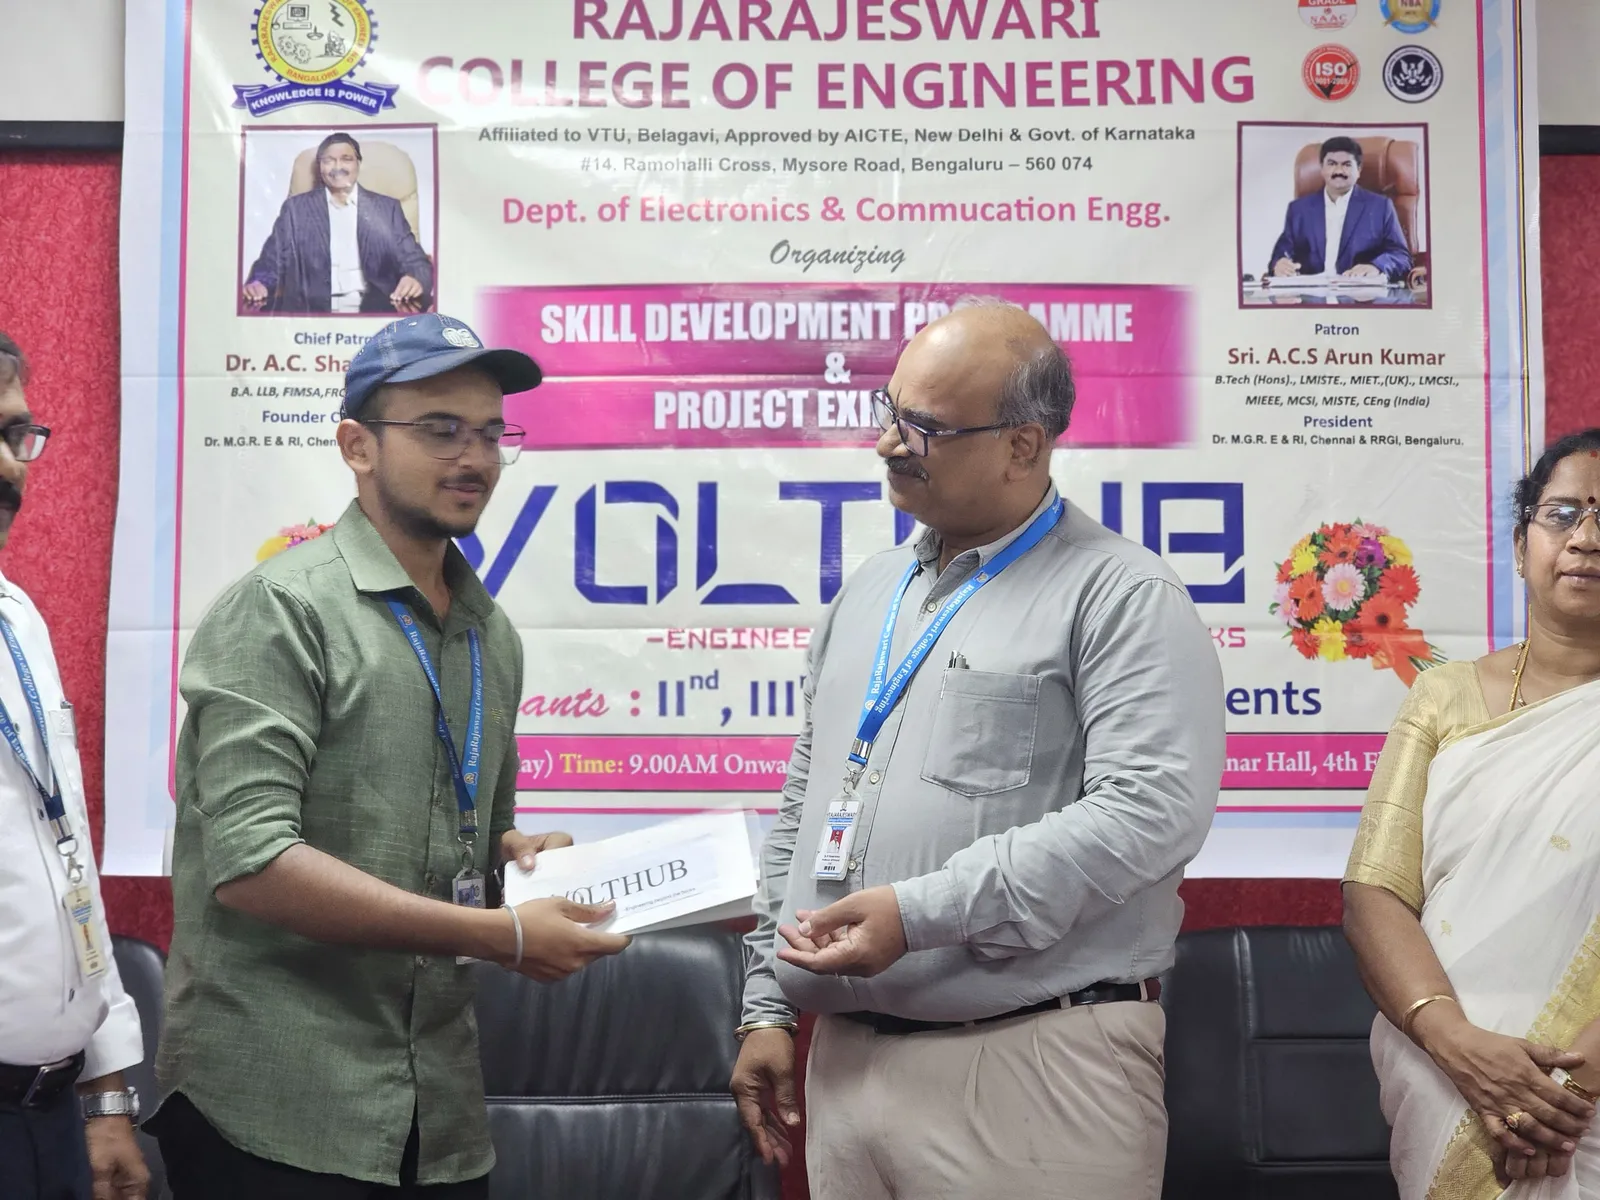
Founder β€” VoltHub Robotics Club

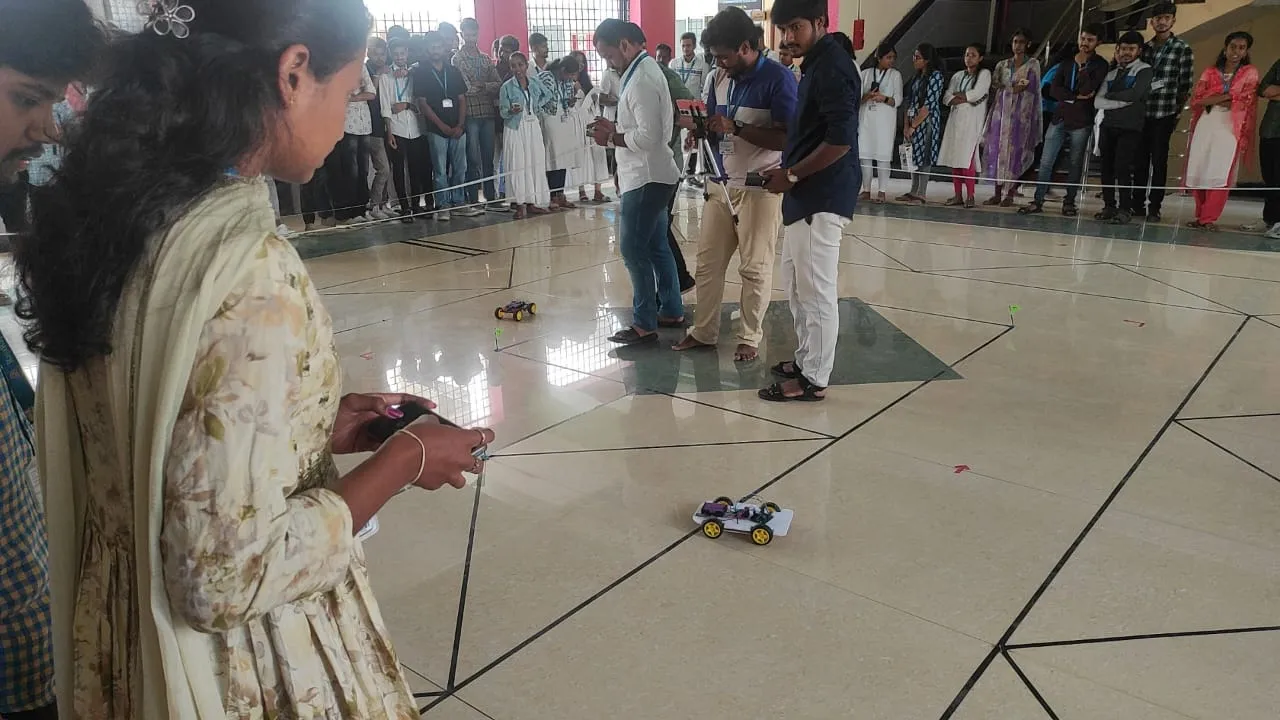
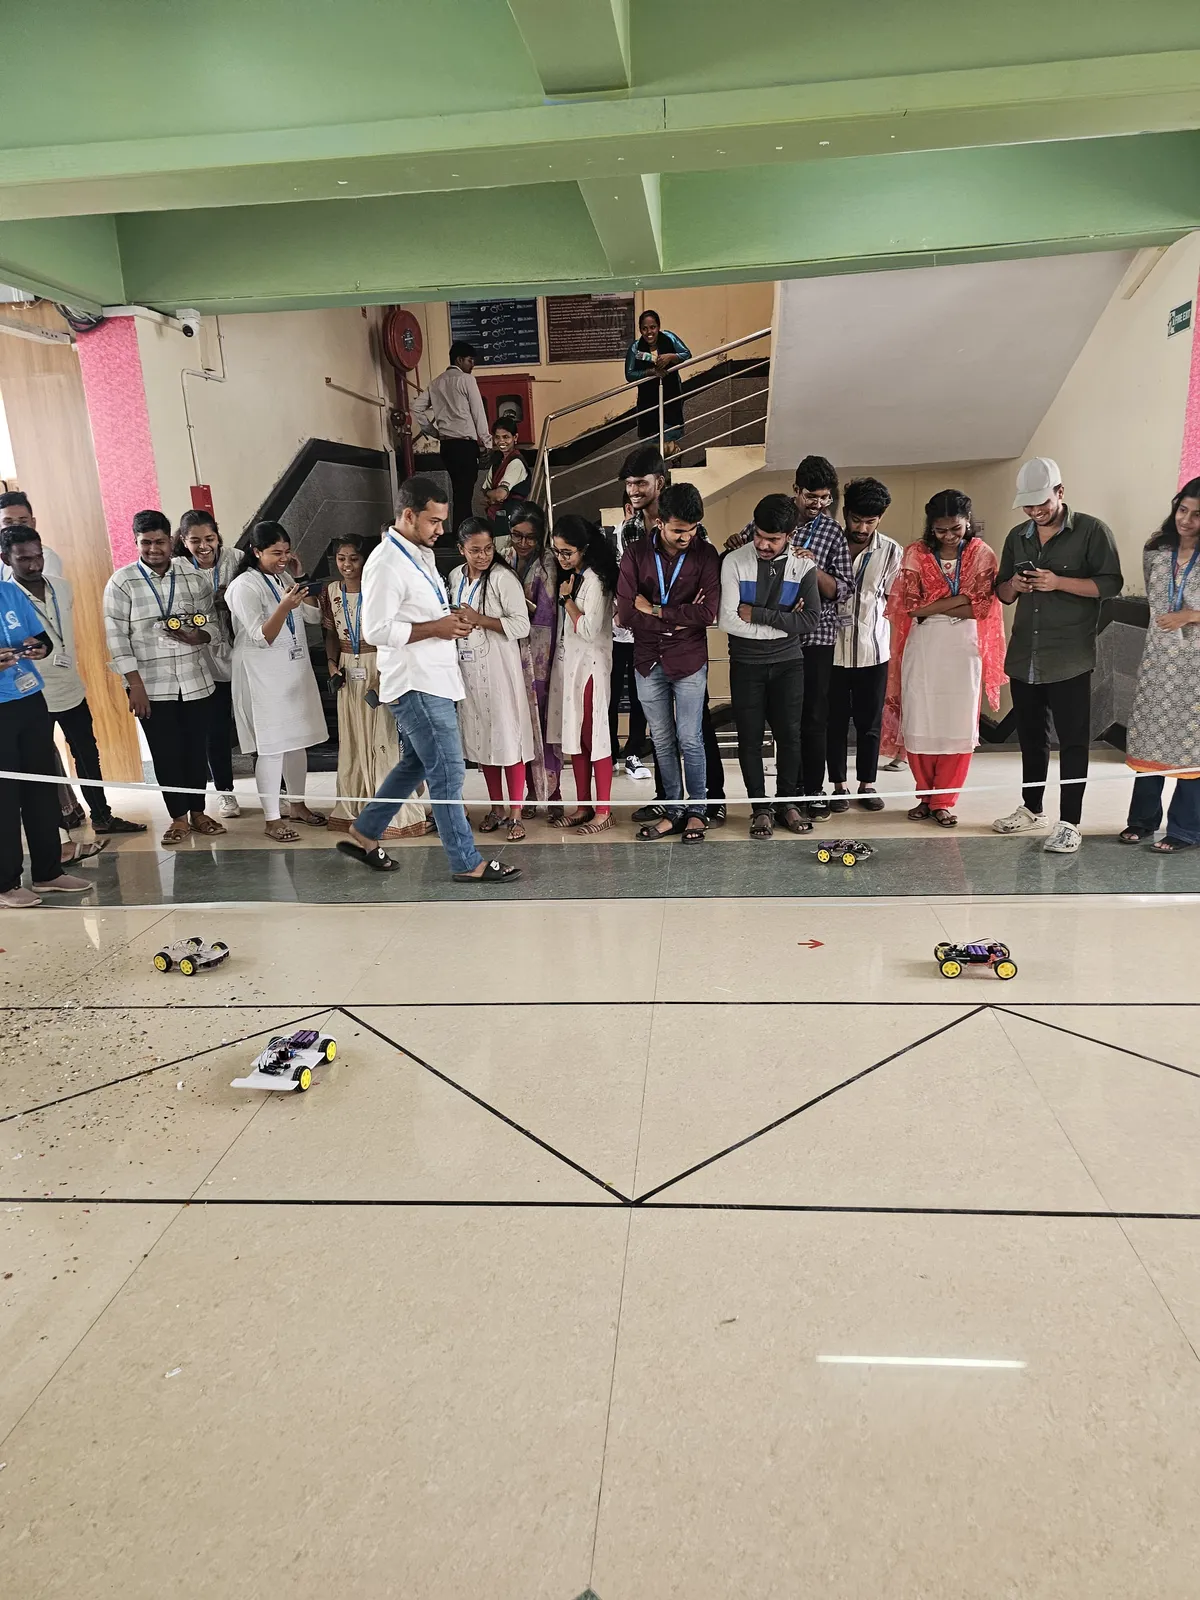
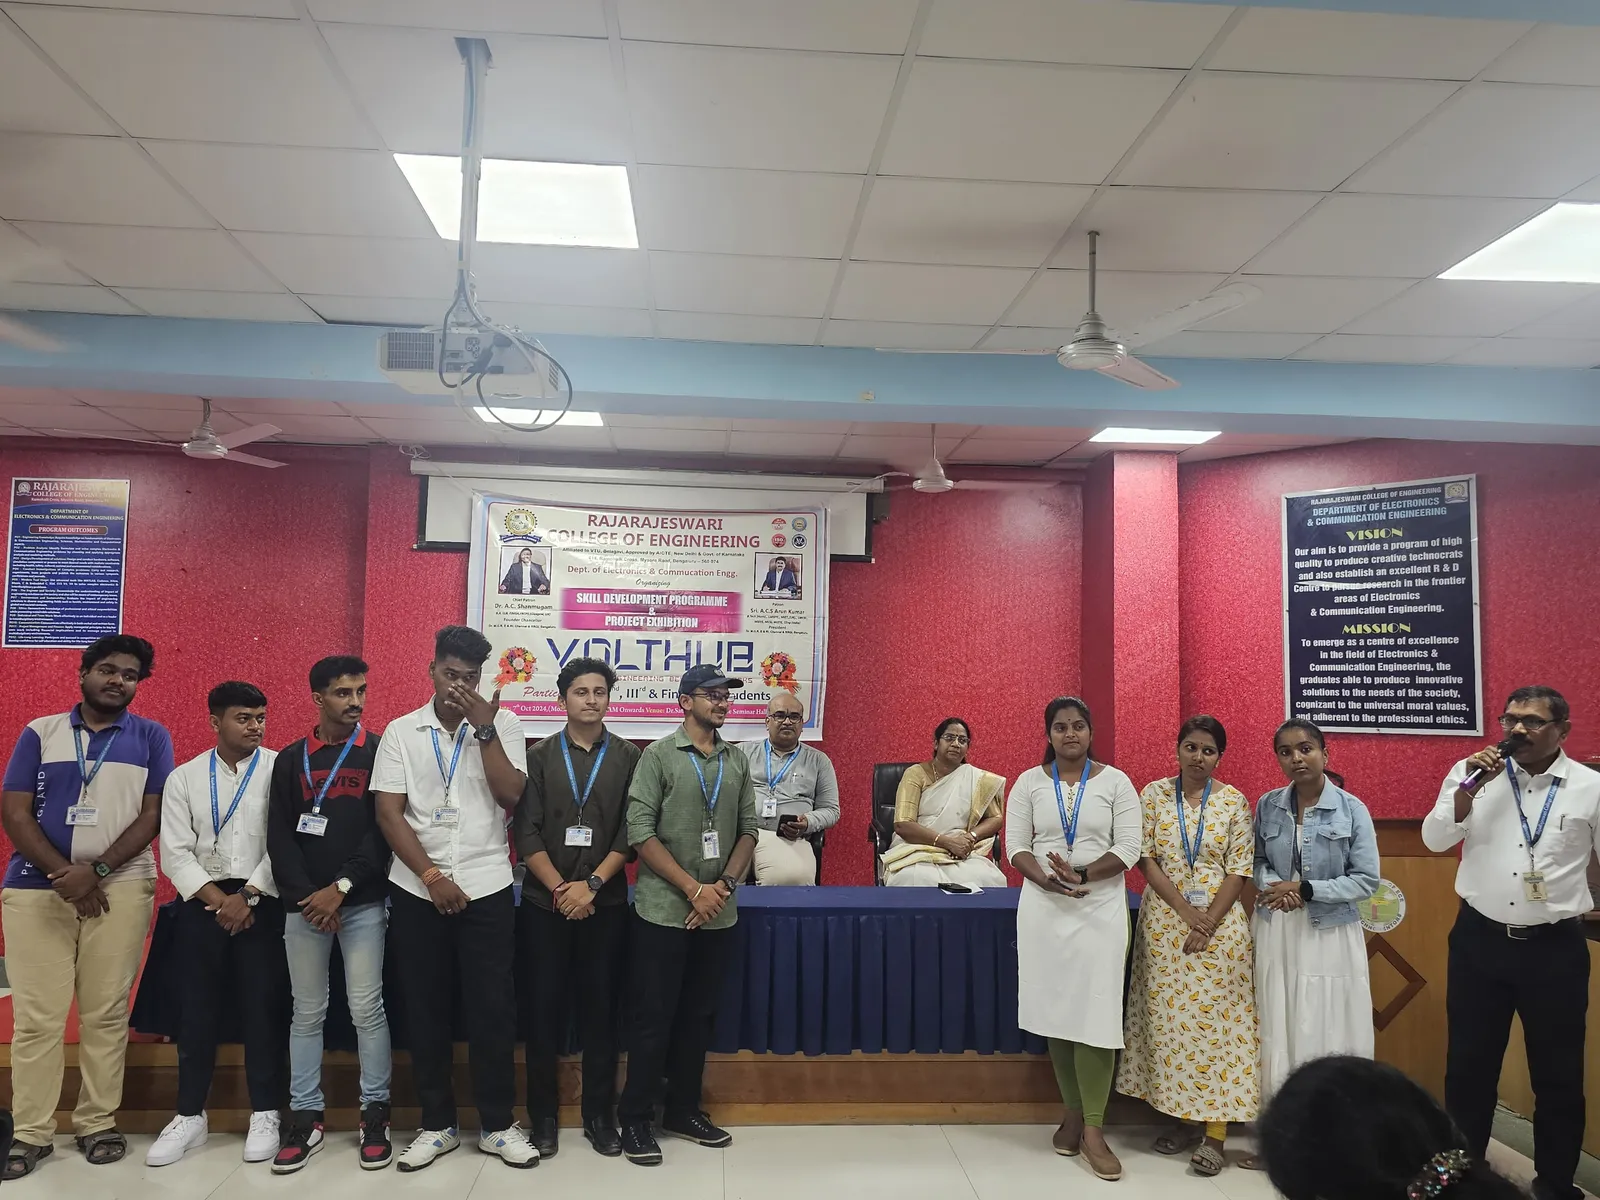
Founded a college robotics club from scratch. Ran 60+ hands-on sessions teaching embedded systems and robotics. Organized a racing day with 14 cars competing on day one. Merit-based selection, zero fluff.
🀝

Partnership Director & Treasurer β€” Rotaract

Rotaract Club of Bangalore & Rotaract Club of RCE

Partnership Director at Rotaract Club of Bangalore β€” managed sponsorships, partnerships, and fundraising.

Previously served as Treasurer for two years at Rotaract Club of Rajarajeswari College of Engineering β€” handled all club finances, budgeting, and fund management.
Things I've built.

Tripod Gripper for Collaborative Robots
VIEW DETAILS
πŸ”’ AI Reference - Actual build proprietary
HARDWARE
Tripod Gripper
Three-finger gripper with on-board electronics and firmware, and a full monitoring app.
Force Sensing Firmware Python SDK
Facade Cleaning Robot V2
VIEW DETAILS
πŸ”’ AI Reference β€” Actual build proprietary
HARDWARE
Facade Cleaning Robot V2
Production-deployed facade cleaning robot featuring LoRa/ESP-NOW communication, AWS integration, and deep telemetry via Compass OS.
ESP32 LoRa AWS Cloud
Kinetic Rain Installation
VIEW DETAILS
HARDWARE
Kinetic Rain
Gallery-scale kinetic art featuring 18 synchronized stepper motors driving sand-weighted spheres in high-precision wave patterns.
TMC2209 UART Slave Kinetic
Neuron β€” Personal AI OS
VIEW DETAILS
SOFTWARE
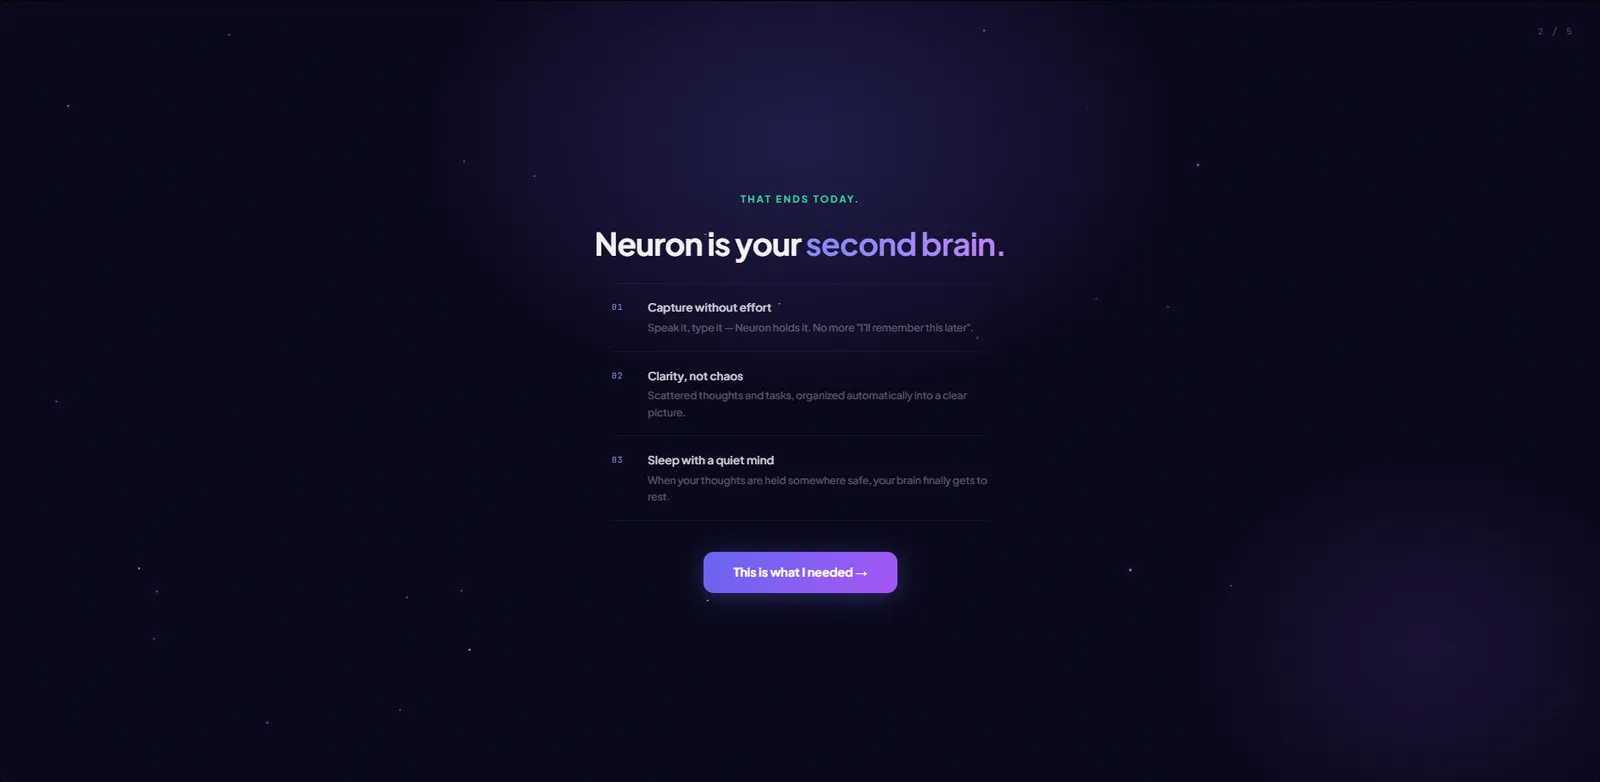
Neuron AI OS
Cognitive OS consisting of Cortex (RAG Ingestion), Locus (Task Engine), and Pulse (Journal) modules running on a multi-model AI backbone.
n8n pgvector Deep RAG
AI Voice Pendant
VIEW DETAILS
HARDWARE
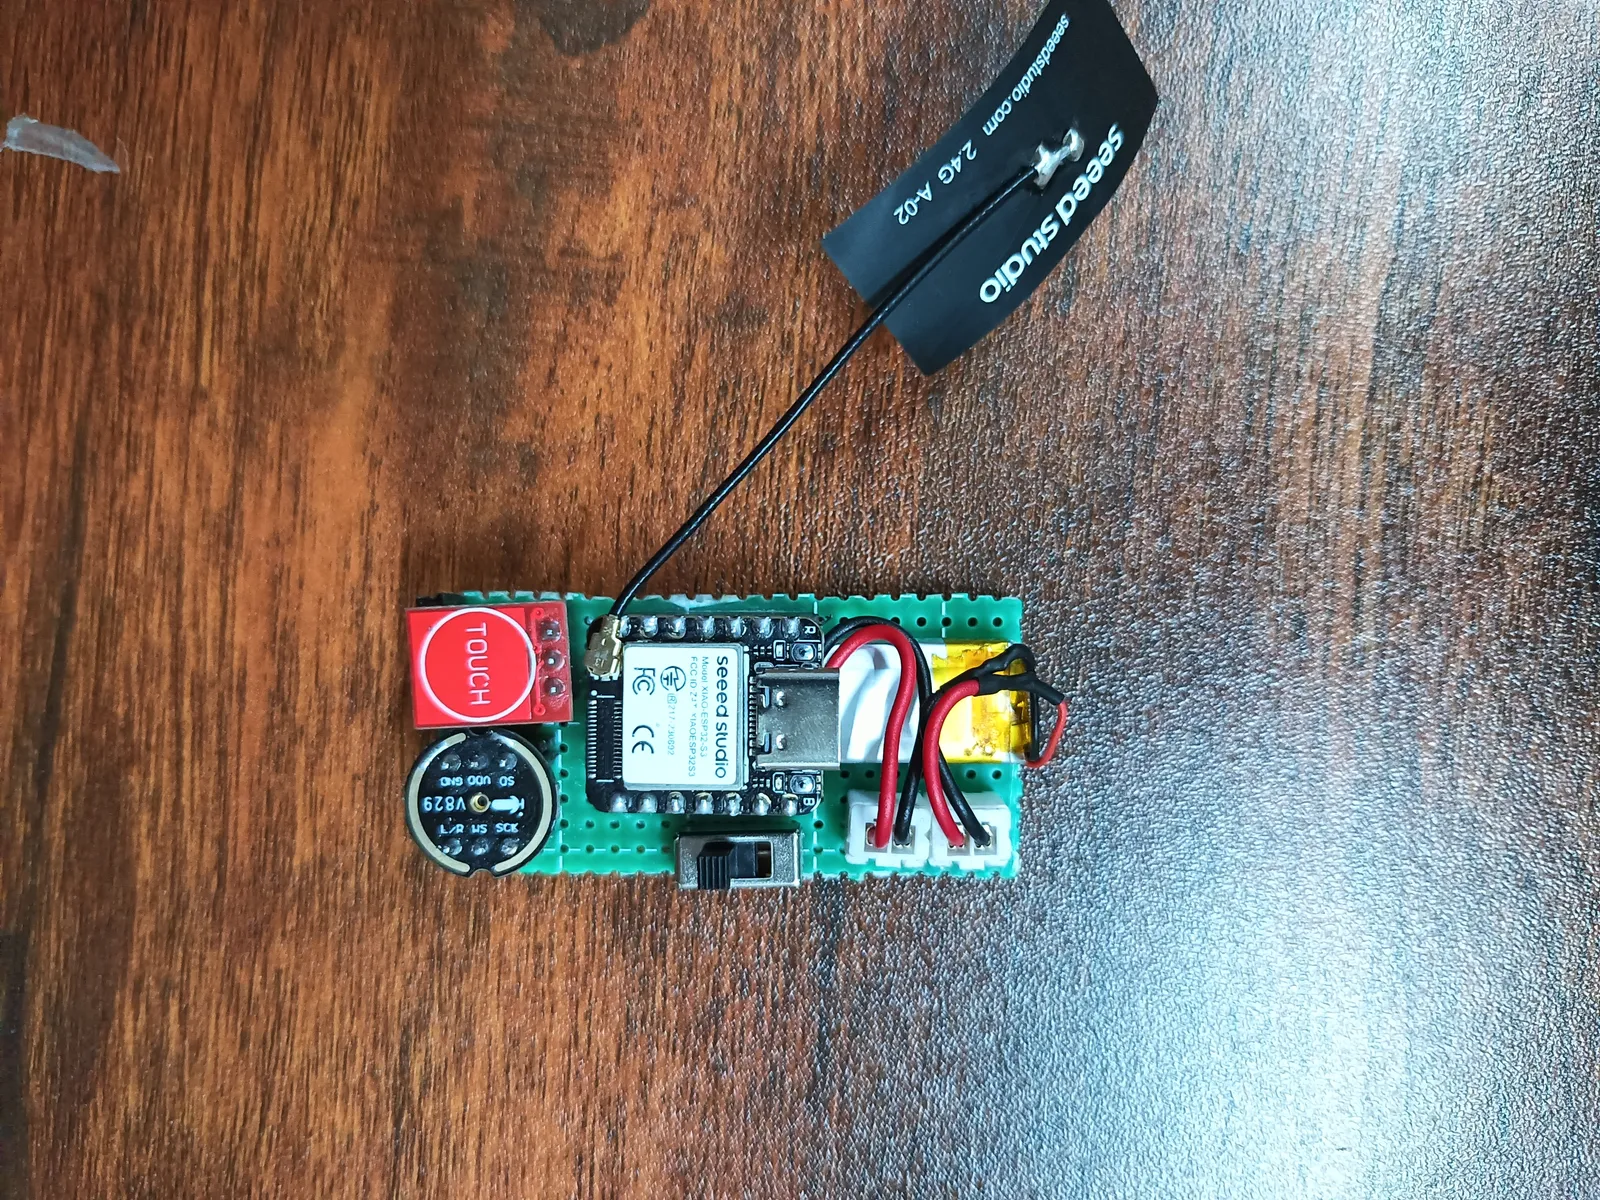
AI Voice Pendant
Wearable ESP32-S3 vocal interface featuring low-latency I2S chunked HTTP streaming, 32x DSP gain boost, and automated asynchronous cloud transcription.
ESP32-S3 MEMS I2S 3D Precision
BLE Gamepad β€” Steering Wheel + Pedals
VIEW DETAILS
HARDWARE
BLE Gamepad Rig
Fully custom, 3D-printed racing peripheral featuring driverless Windows HID integration and hardware-level ADC conflict resolution.
ESP32 BLE HID 3D Print
[ + More Builds ]

The stack that ships robots.

// Embedded & Hardware
// Mechanical Design
// Software & Backend
// AI & Tooling
ESP32
Arduino
LoRa
MQTT
BLDC Motors
Stepper Motors
RS485
I2C
SPI
Schematics & BOM
Embedded C
C++
UART
GPIO
ADC
PWM
Interrupt Handling
OTA Updates
ESP-IDF
Arduino Framework
Sensor Fusion
Motor Tuning
FreeRTOS
SLAM Nav
Onshape
Production CAD
3D Printing
Manufacturing SOPs
System Architecture
Wiring Harness Design
Prototyping
CoppeliaSim
Assembly Design
Fastener Selection
Flask
React
Supabase
AWS
PostgreSQL
REST APIs
WebSockets
Edge Functions
Vector Search
n8n Workflows
RAG Systems
LangGraph
OpenRouter
CrewAI
Vector DBs
Gemini API
// Embedded
ESP32 Arduino ESP-IDF Embedded C C++ UART I2C SPI GPIO ADC PWM LoRa MQTT BLDC Motors Stepper Motors RS485 Schematics & BOM OTA Updates Sensor Fusion Motor Tuning Interrupt Handling FreeRTOS SLAM Navigation
// Mechanical
Onshape Production CAD 3D Printing Prototyping Assembly Design Wiring Harness Design Manufacturing SOPs System Architecture Fastener Selection
// Software
Flask React Supabase AWS PostgreSQL REST APIs WebSockets Edge Functions Vector Search
// AI & Tooling
n8n Workflows RAG Systems LangGraph OpenRouter CrewAI Vector DBs Gemini API

Let's build something real.

I'm open to robotics, embedded systems, and hardware-first startup roles in Bengaluru.
Not looking for pure software work β€” I want to be in the lab, in the field, shipping systems that exist in the physical world.
SYSTEM ONLINE
BENGALURU, IND UTC+5:30 v2.0.26